End-effectors and fingers
Show workpiece contact, grasping intent and replaceable features. Define surface and edge requirements without assuming a concept proves holding performance.
APPLICATION REVIEW / ROBOTICS MECHANICAL PARTS
A gripper finger, sensor mount and joint cover serve different purposes. Connect geometry to payload, motion and service access before selecting a sample route or releasing repeat components.
KeepWin coordinates partner-supported review. Exact material, responsible operations, process availability, dimensions, inspection, commercial quantities and timing are confirmed in the project proposal; no universal capability or certification is promised.
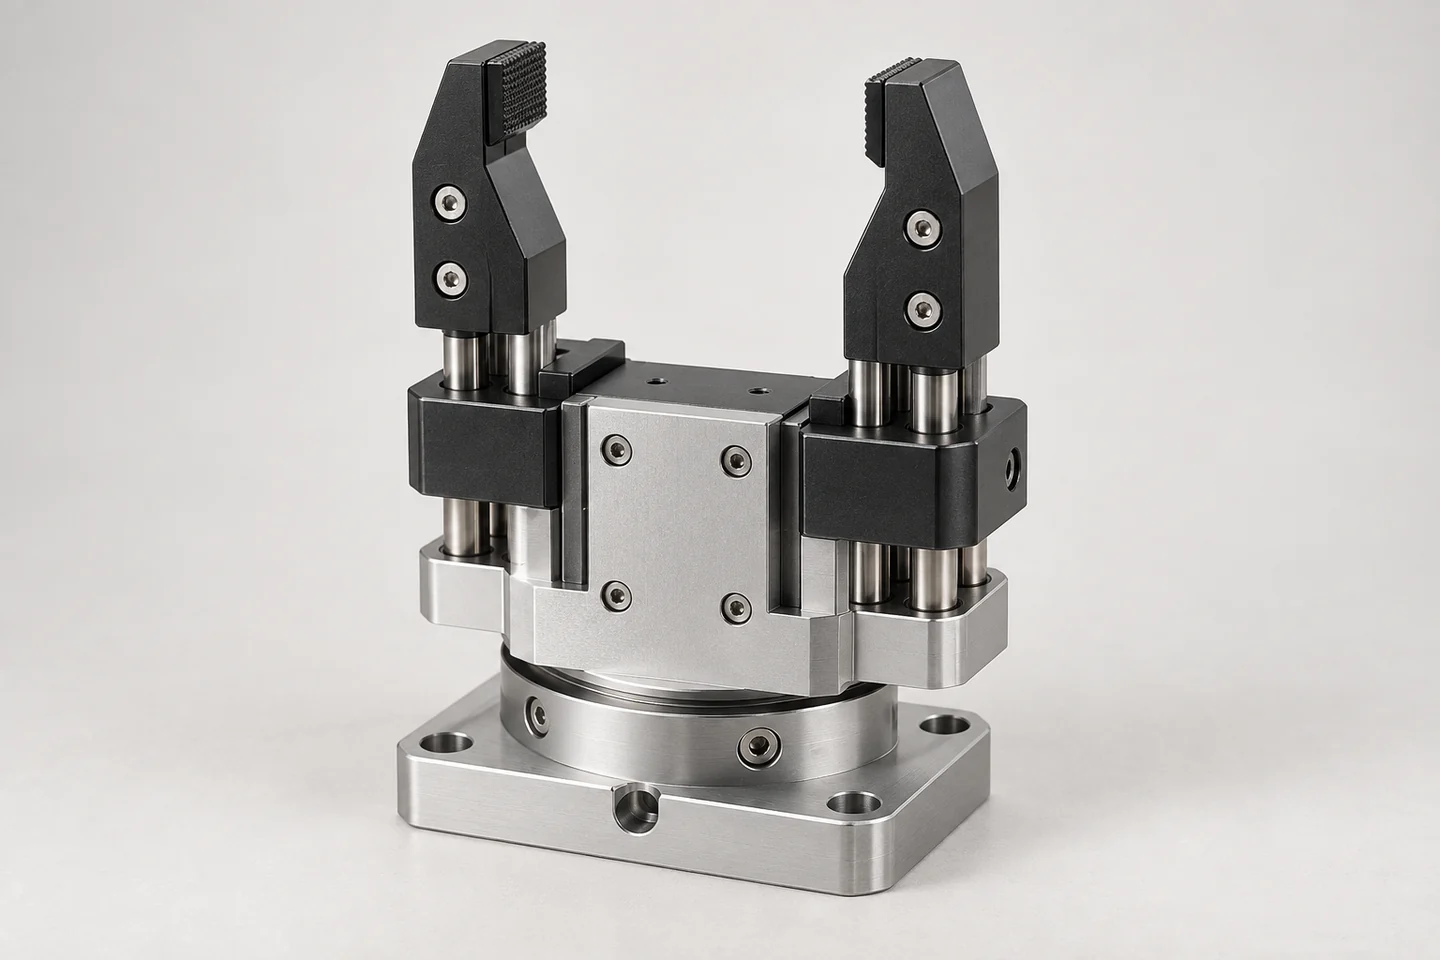
Generated robotics component concept. It does not demonstrate an operating robot, payload rating, repeatability or safety performance.
01 / COMPONENT ROLE
Mechanical design review needs the neighbouring components and operating context. A standalone rendering does not define the robot configuration.
Show workpiece contact, grasping intent and replaceable features. Define surface and edge requirements without assuming a concept proves holding performance.
Identify mounting datums, alignment and adjustment needs. Provide the mating references and accepted installed condition.
Map motion, access, cable path and nearby components. Identify relevant protection and service requirements separately from appearance.
02 / MOTION REVIEW
Static dimensions can miss interference at another position. Explain the required envelope and the conditions represented by the proposed check.
Show relevant positions and neighbouring surfaces. Mark prohibited interference and permitted contact.
Describe the use, load direction and operating assumptions. Required evaluation and acceptance criteria remain explicit rather than a universal rating.
Identify routing, connectors, removal paths and adjustable features. Review any shape change against access and motion.
Map locating, gripping and repeated-contact areas. Confirm exact material, texture and relevant use checks for the actual workpiece.
03 / PROCESS COMPARISON
A quick assembly model and a repeat operating part need different preparation. Include surface, hardware and final checks in the offered scope.
| Route | Review | Approval boundary |
|---|---|---|
| Machining | Interfaces, tool access and finishing. | Measured configuration and agreed features. |
| Additive development | Shape iteration and access. | Represented material/process and questions. |
| Molding | Repeat part, inserts and tooling. | Approved resin/tooling configuration. |
| Sheet fabrication | Brackets, covers and bends. | Final assembled geometry and edges. |
04 / CONFIGURATION CONTROL
A changed finger or mounting offset may invalidate an earlier check. Keep the approval tied to the assembly it represented.
Identify robot/tool mounting, workpiece and accessory revisions where relevant. Record the accepted component orientation.
Specify supplied or buyer-provided fasteners, inserts and mating parts. Agree incoming condition and fit responsibility.
Review material, geometry, surface and route changes against movement, contact and previous evidence. Name the release owner.
Confirm responsible manufacture, finish and checks. This page does not claim complete robot integration or certify a robot cell.
05 / ACCEPTANCE
Dimensions, fit and an operating trial cover different scopes. Define methods and configuration before extending a sample decision.
| Area | Define | Record |
|---|---|---|
| Fit | Mounting datums and mating references. | Final state and assembled configuration. |
| Motion | Relevant positions and clearance criteria. | Method and represented envelope. |
| Contact | Workpiece, surface and required use check. | Conditions and responsible approval. |
| Identity | Part/revision, material and finish. | Quantity and relevant records. |
06 / QUOTATION
Specify the sample question and operating component separately where they differ. Price comparison should include the preparation and evidence needed for release.
Send part and assembly files, motion/workpiece references, material, finish, critical features, hardware scope, quantities and destination.
Identify preparation, manufacture, secondary operations, hardware, final-state checks, records and protective packing. Confirm any externally supplied inputs.
Agree sample limitations and the owner of robot/system evaluation. Numerical limits, process availability, MOQ and timing require actual proposal review.
07 / QUESTIONS
Provide the moving and contact relationship rather than a part model alone.
No. It is a generated concept without operating results. Define the required configuration and evaluation.
Only its represented questions. Material, process, contact and use requirements need review before operating approval.
Provide mounting datums, sensor reference, alignment needs, adjustment range intent and final installed configuration.
Only the agreed scope. Identify component supply, engagement and incoming acceptance responsibilities.
No. Component manufacture and system integration/safety acceptance are separate scoped responsibilities.
PREPARE THE NEXT DECISION
Include controlled files, mounting/workpiece references, movement envelope, loads and relevant use conditions, cable/access needs, material, finish, checks, quantities and destination.
sales@keepwinco.comAn enquiry starts a team review. Material, fit, quantity, schedule, operation responsibility and supporting records are confirmed in the proposal; this form does not create an order or an instant price.
Start with what you know. Review your details before sending; no account needed.
Start parts inquiry →Your project is saved securely only when submission succeeds.